Ben Davis

I'm a fourth year Ph.D. student at UC Berkeley with Hannah Stuart. My research interests involve robot design for manipulation, with a focus on building and learning with hardware that's mechanically robust and adaptable for real-world use. I'm supported by the NSF Graduate Research Fellowship.

I did my undergrad at The University of Texas at Austin, where I worked on soft wearable sensing with Nanshu Lu and haptic motor learning with Ann Majewicz Fey.

Google Scholar     LinkedIn     Github

bendavis at berkeley dot edu
Profile photo

2026

Our tactile sensing paper was a spotlight presentation and award candidate at the IROS 2026 Workshop on Touch-to-Action.

2026

Our poster won Best Poster Runner-Up at the ICRA 2026 Workshop, "Human-Inspired Principles for Robotic Dexterous Manipulation"!

2026

Our paper was accepted to IEEE Humanoids 2026.

2026

Our paper was accepted to IEEE ICRA 2026.

2025

Our paper was accepted to Frontiers in Robotics and AI.
For a more up-to-date list, visit my Google Scholar

A Quasi-Direct-Drive Underactuated Asymmetric Hand for Dexterous and Efficient Grasping and Manipulation

Best Poster Runner-Up

Benjamin Davis, Chase Kidder, Hannah S. Stuart
IEEE Humanoids 2026
Paper  •   Website

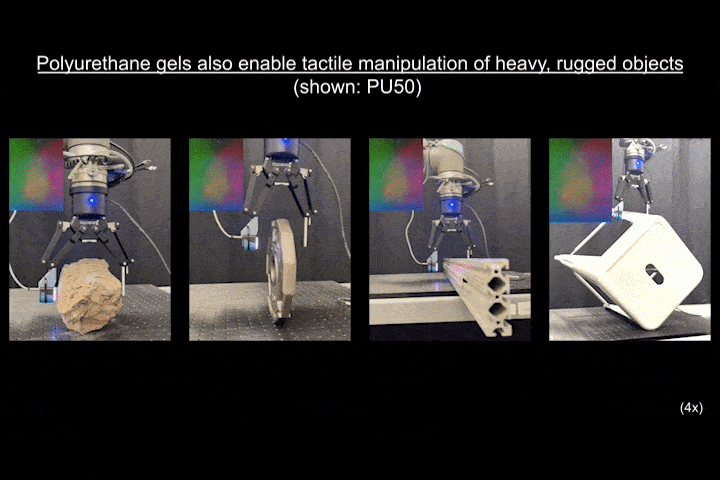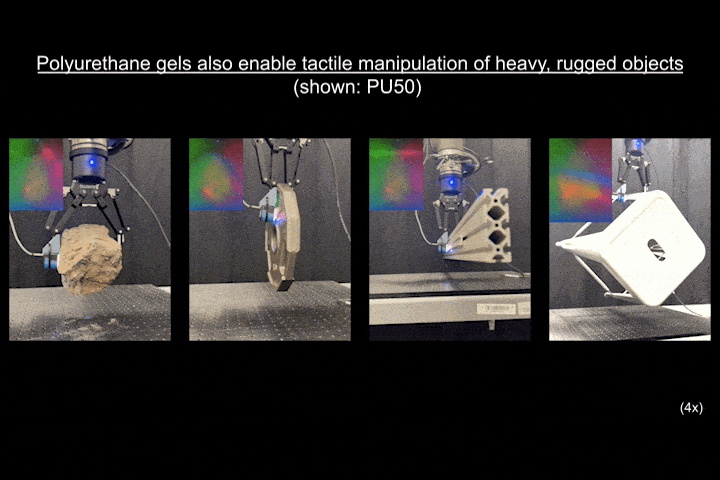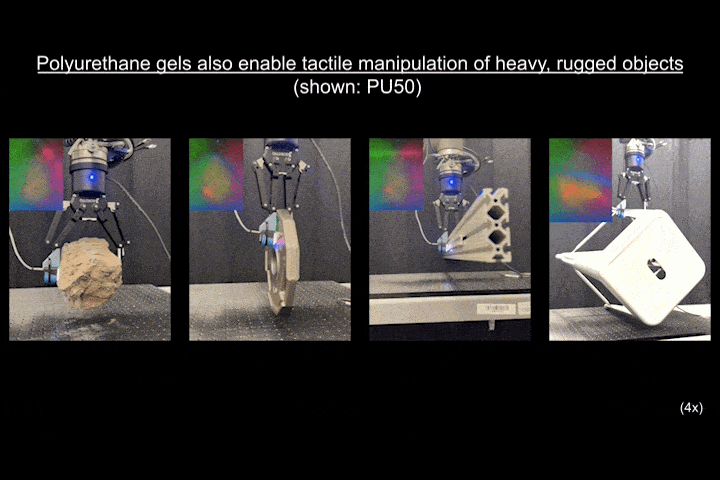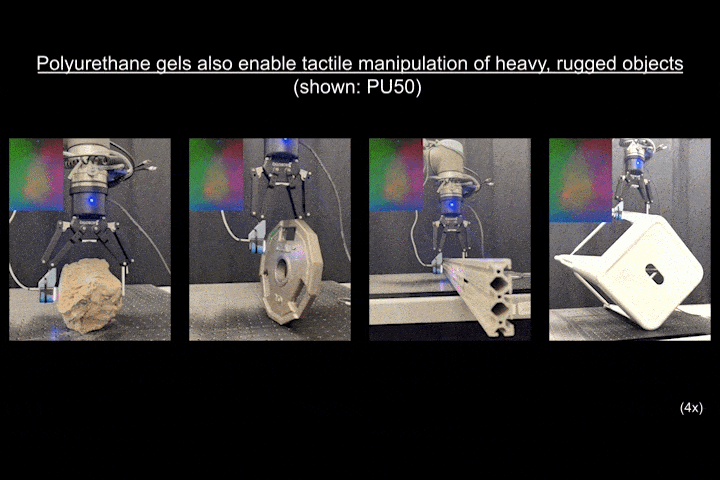
Characterizing the Resilience and Sensitivity of Polyurethane Vision-Based Tactile Sensors

Spotlight — Award Candidate

Benjamin Davis, Hannah S. Stuart
Paper  •  Part files
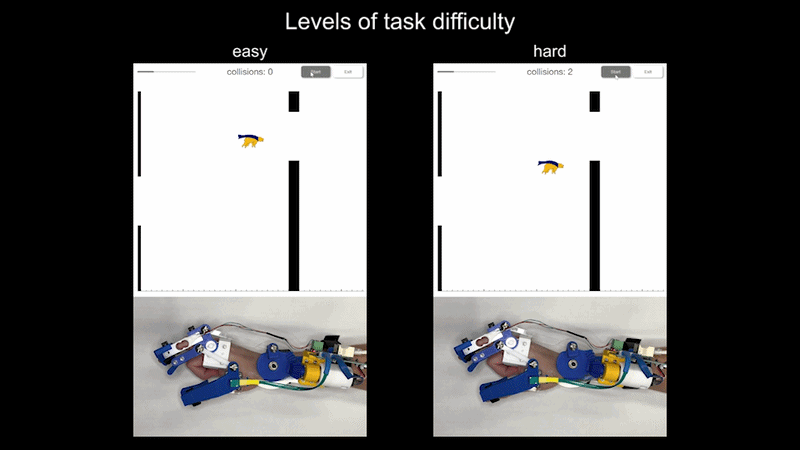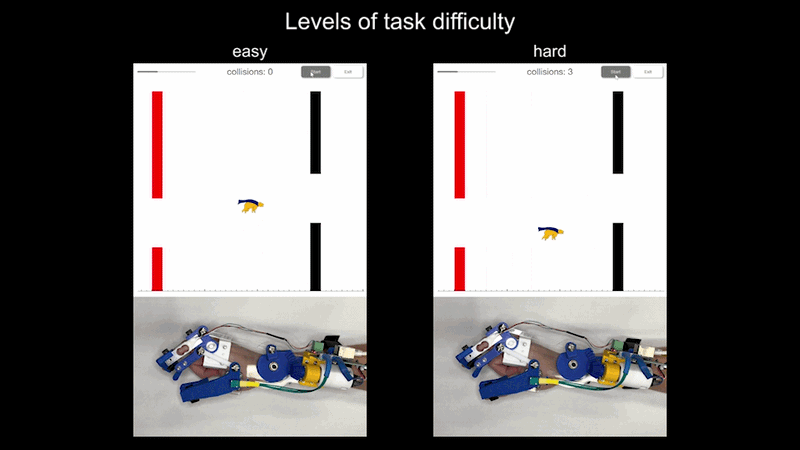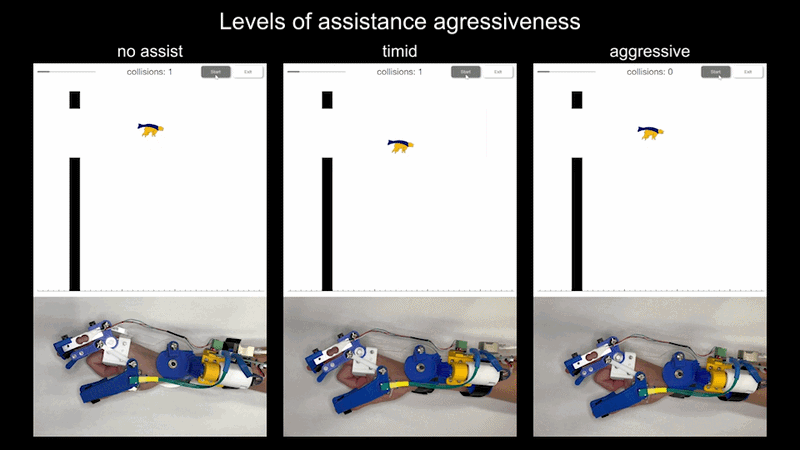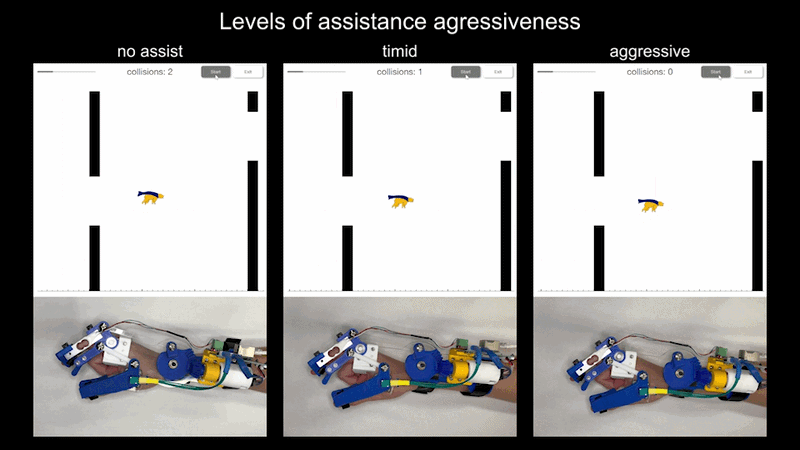
Proactive Grasp Assistance in a Robotic Hand Exoskeleton Improves Performance and Preference in Challenging Tasks

Benjamin Davis, Emily Huynh, Hannah S. Stuart
IEEE ICRA 2026
Paper (coming soon)
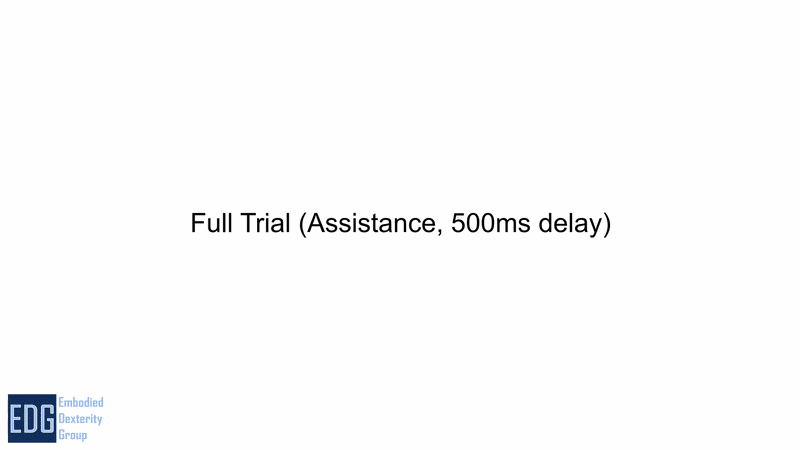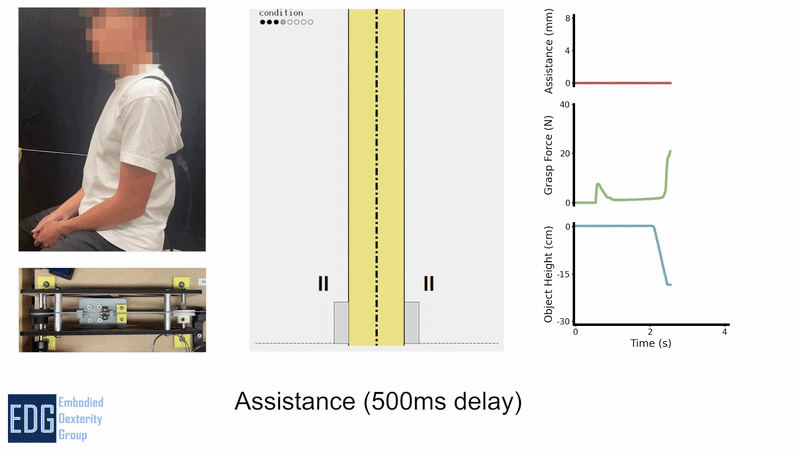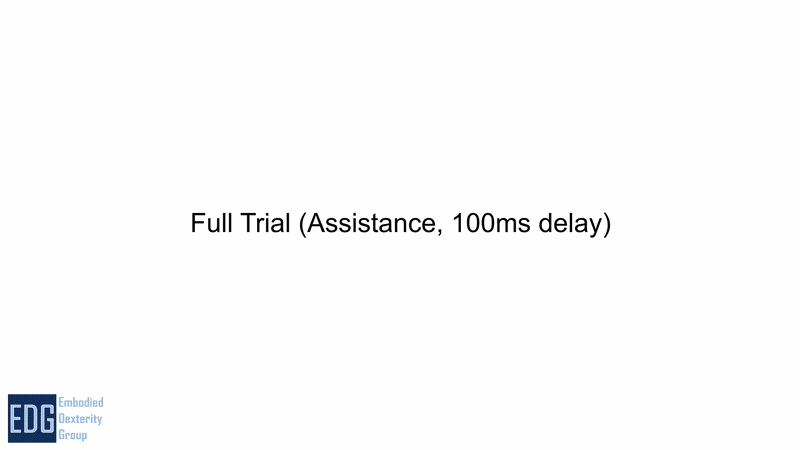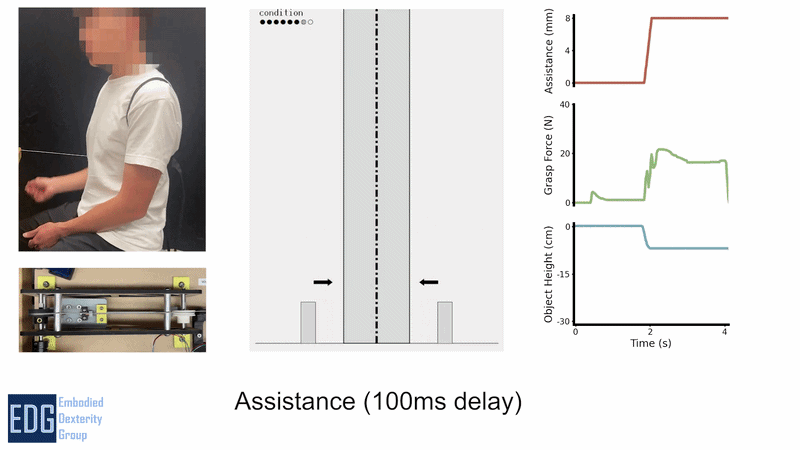
Agency-Preserving Robotic Assistance for Grasp Slip Recovery in Body-Powered Prostheses

Benjamin Davis, Michael Abbott, Hannah S. Stuart
Frontiers in Robotics and AI (2025)
Paper

2026

Resilient Vision-Based Tactile Sensing with Polyurethane Gels
Touch-to-Action (IROS 2026)
Spotlight — Award Candidate

2026

Design of a Hybrid Direct-Drive and Underactuated Linkage-Driven Dextrous Hand for Efficient Grasping and Manipulation
Sensors and Actuators for Dexterous Manipulation (IROS 2026)

2026

Design of a Hybrid Direct-Drive and Underactuated Linkage-Driven Dextrous Hand for Efficient Grasping and Manipulation
Human-Inspired Principles for Robotic Dexterous Manipulation (ICRA 2026)
Best Poster Runner-Up